Engineering
A highly modular, precision dexterous humanoid robot hand with quasi-direct drive actuation. Each finger is built from four identical custom-designed actuators, giving the hand 20 precise degrees of freedom.
System Architecture
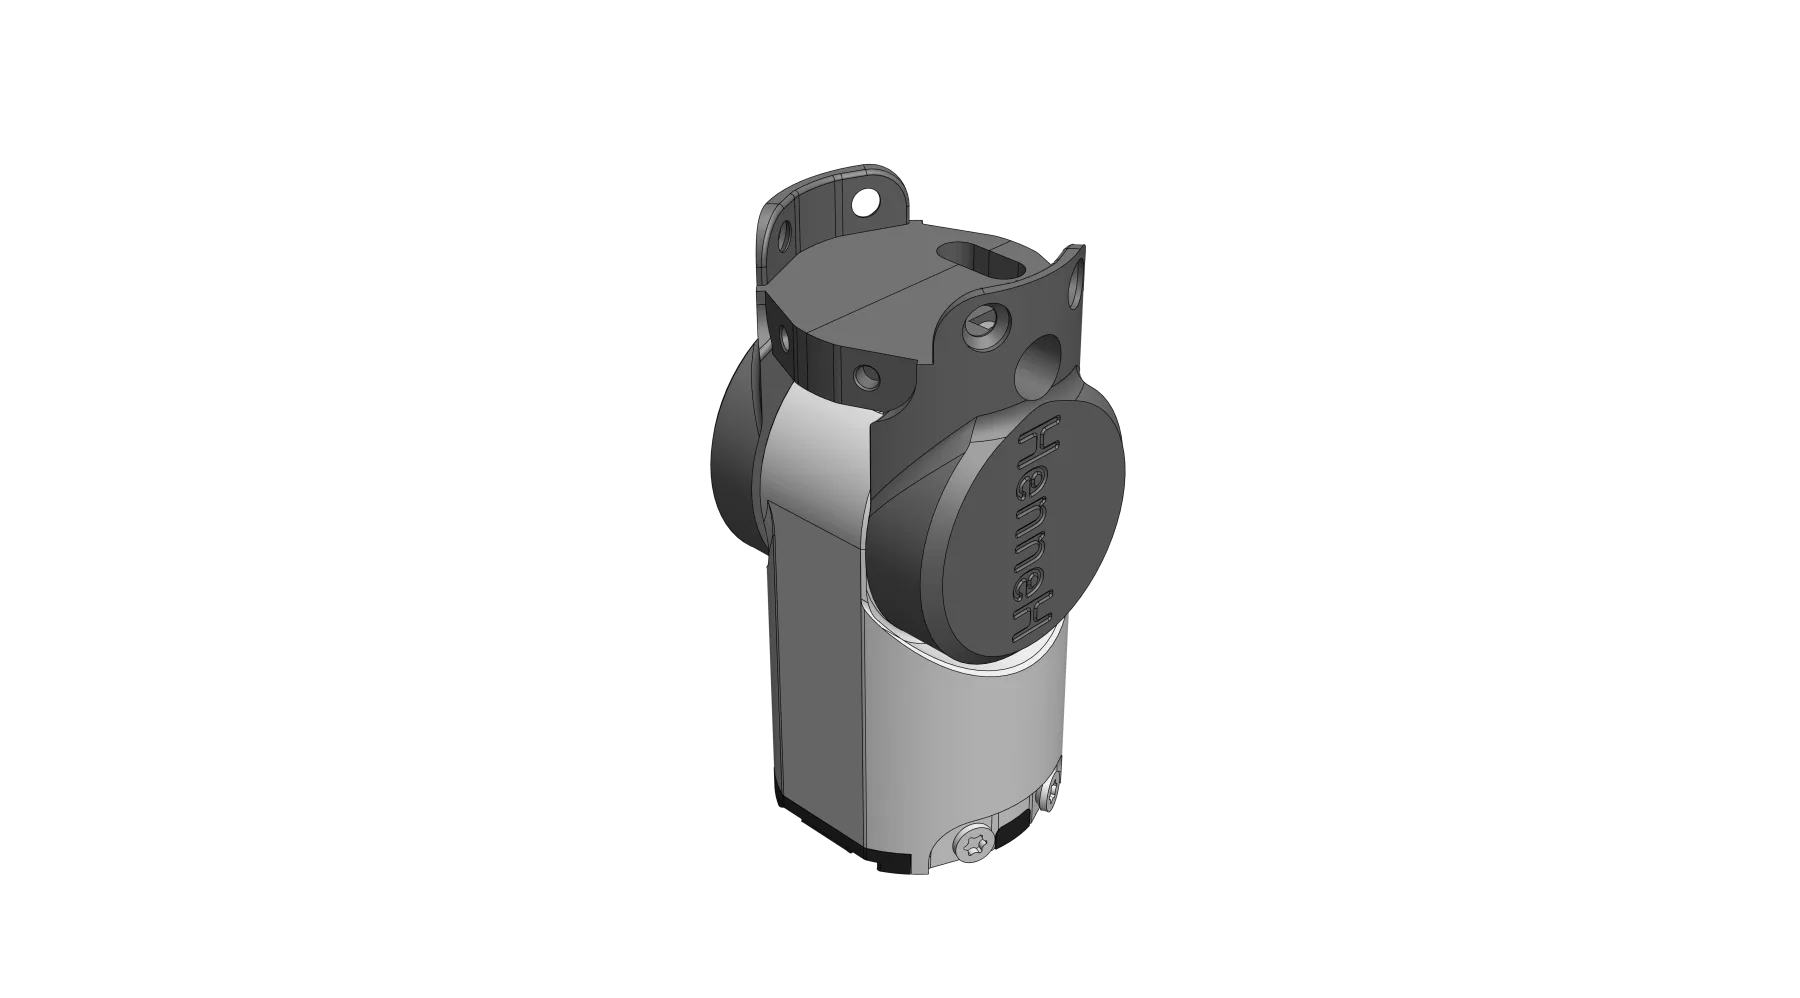
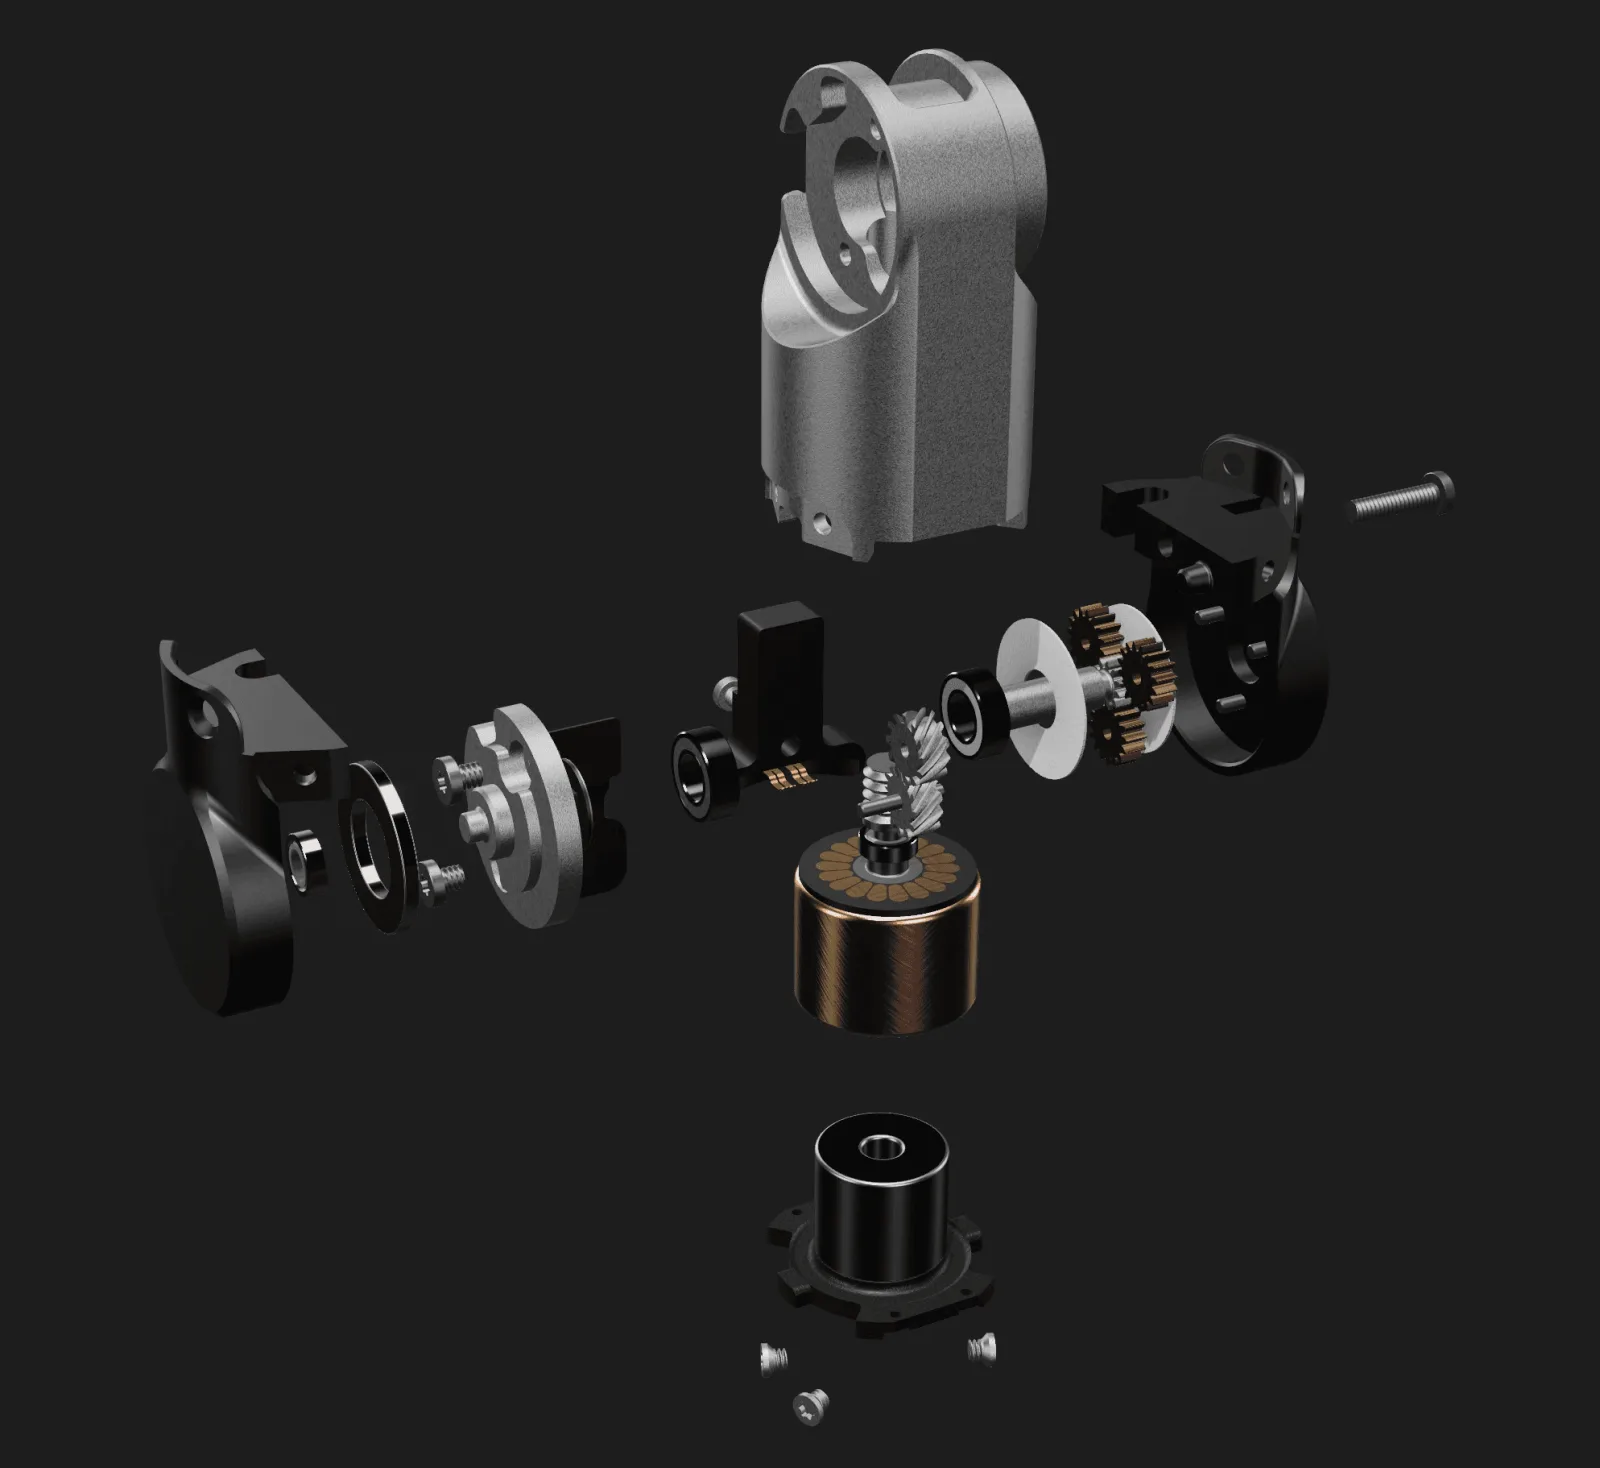
Each joint of the hand consists of an identical self-interconnecting modular actuator.
DFM and DFA
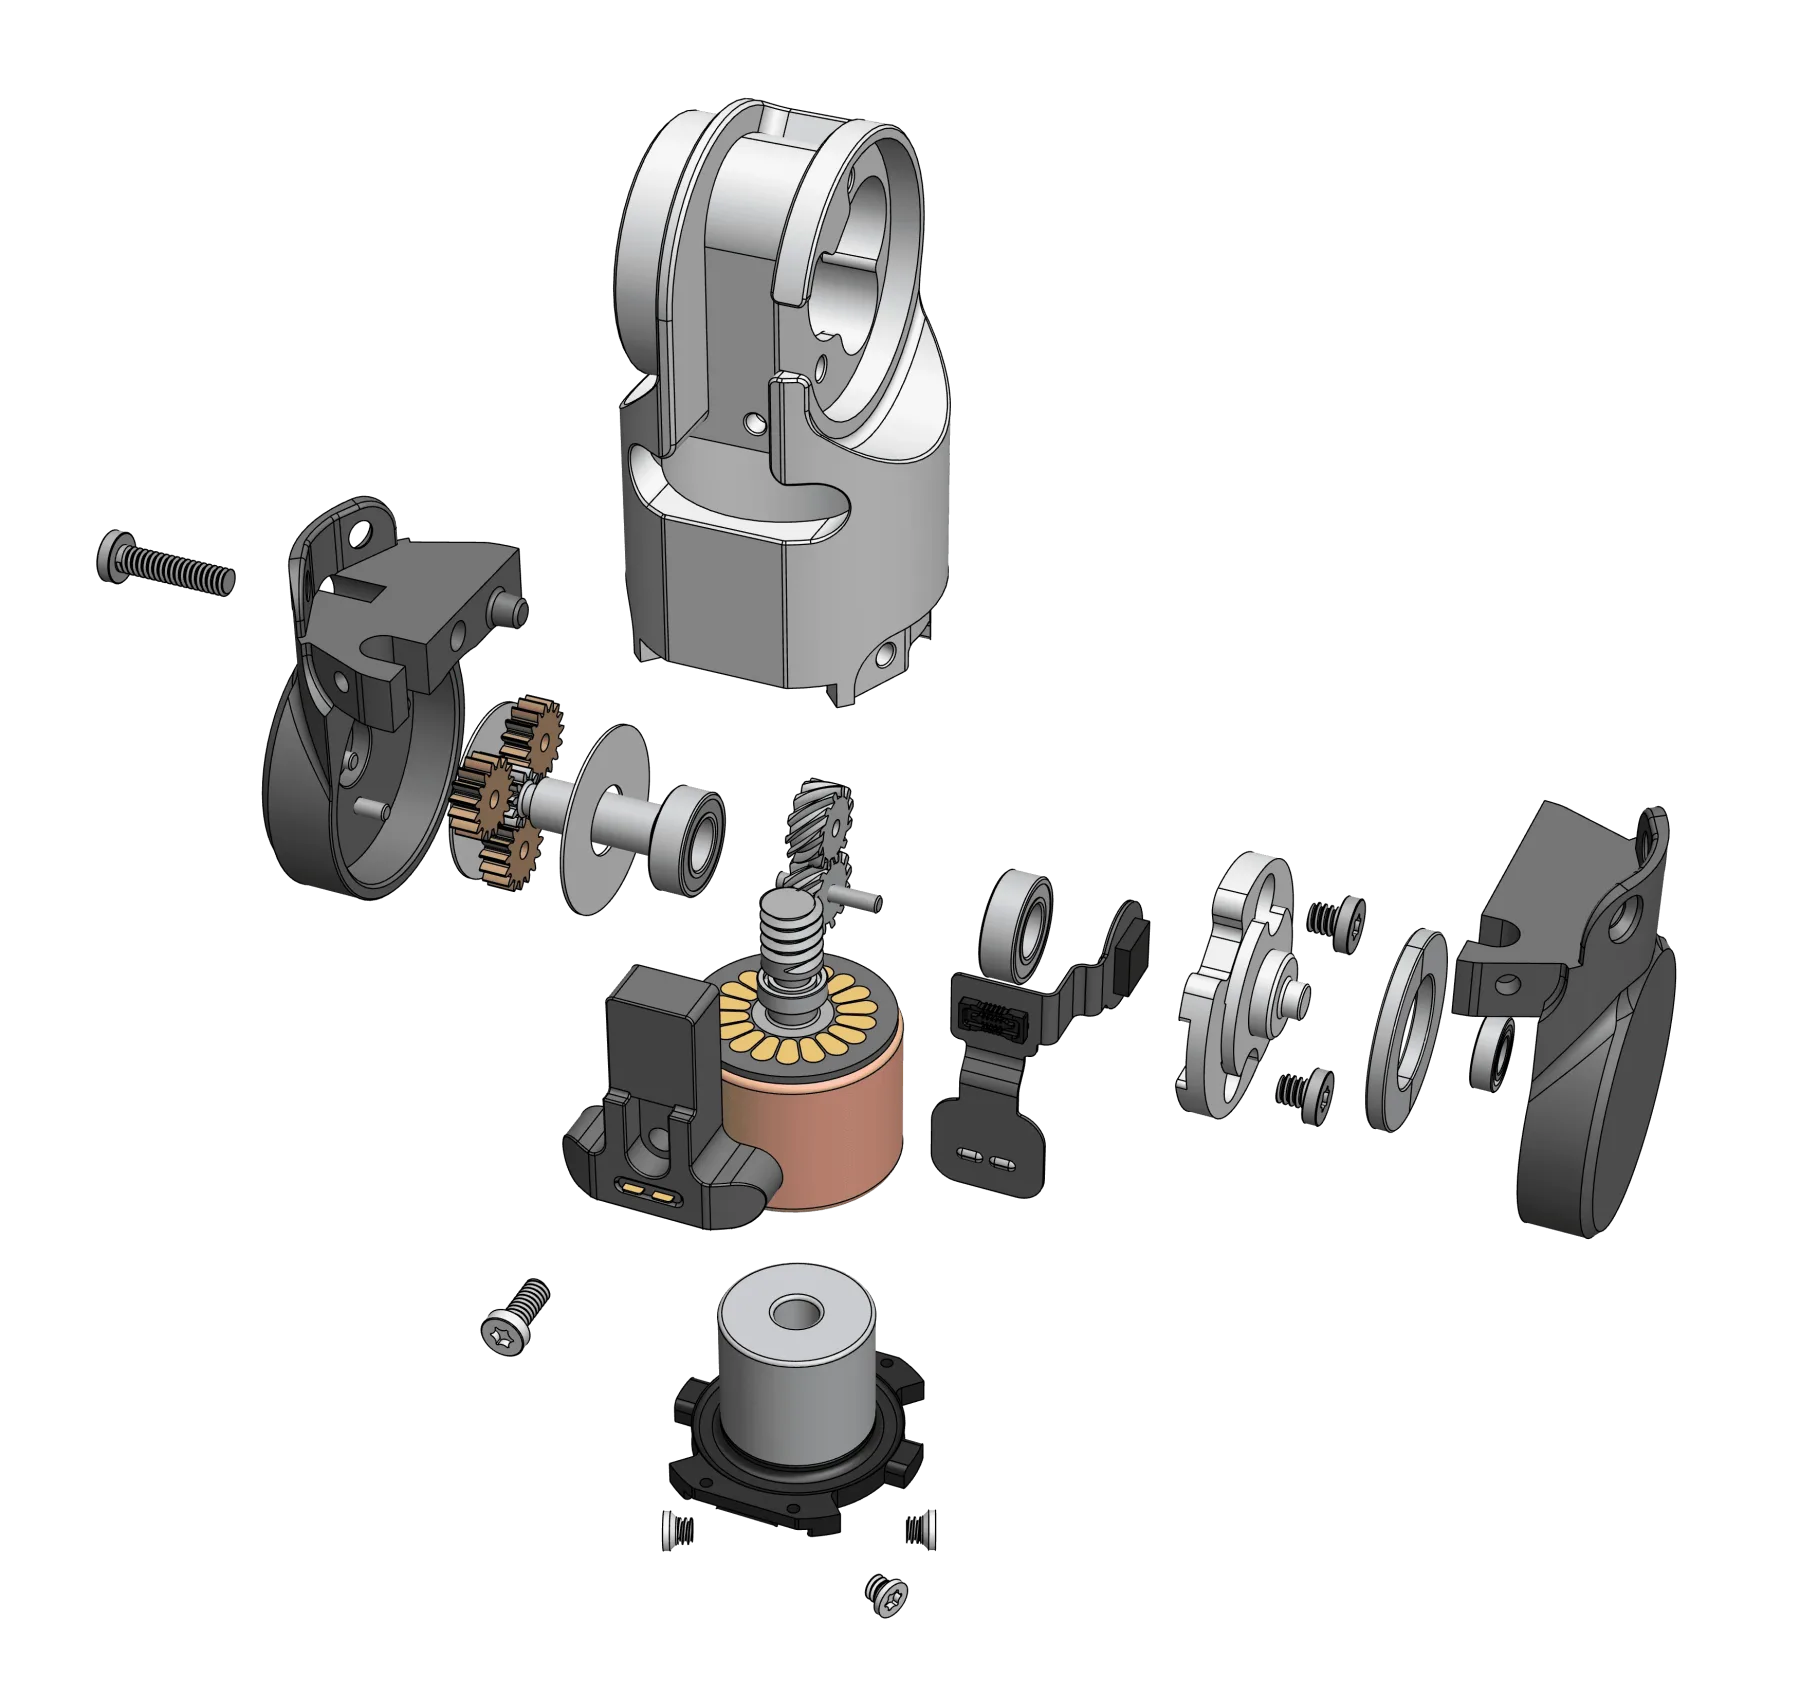
High RPM coreless motor with a back drivable worm gear to transfers rotational power perpendicularly to drive a planetary gear which subsequently drive each joint. All in highly optimized space-efficient design.
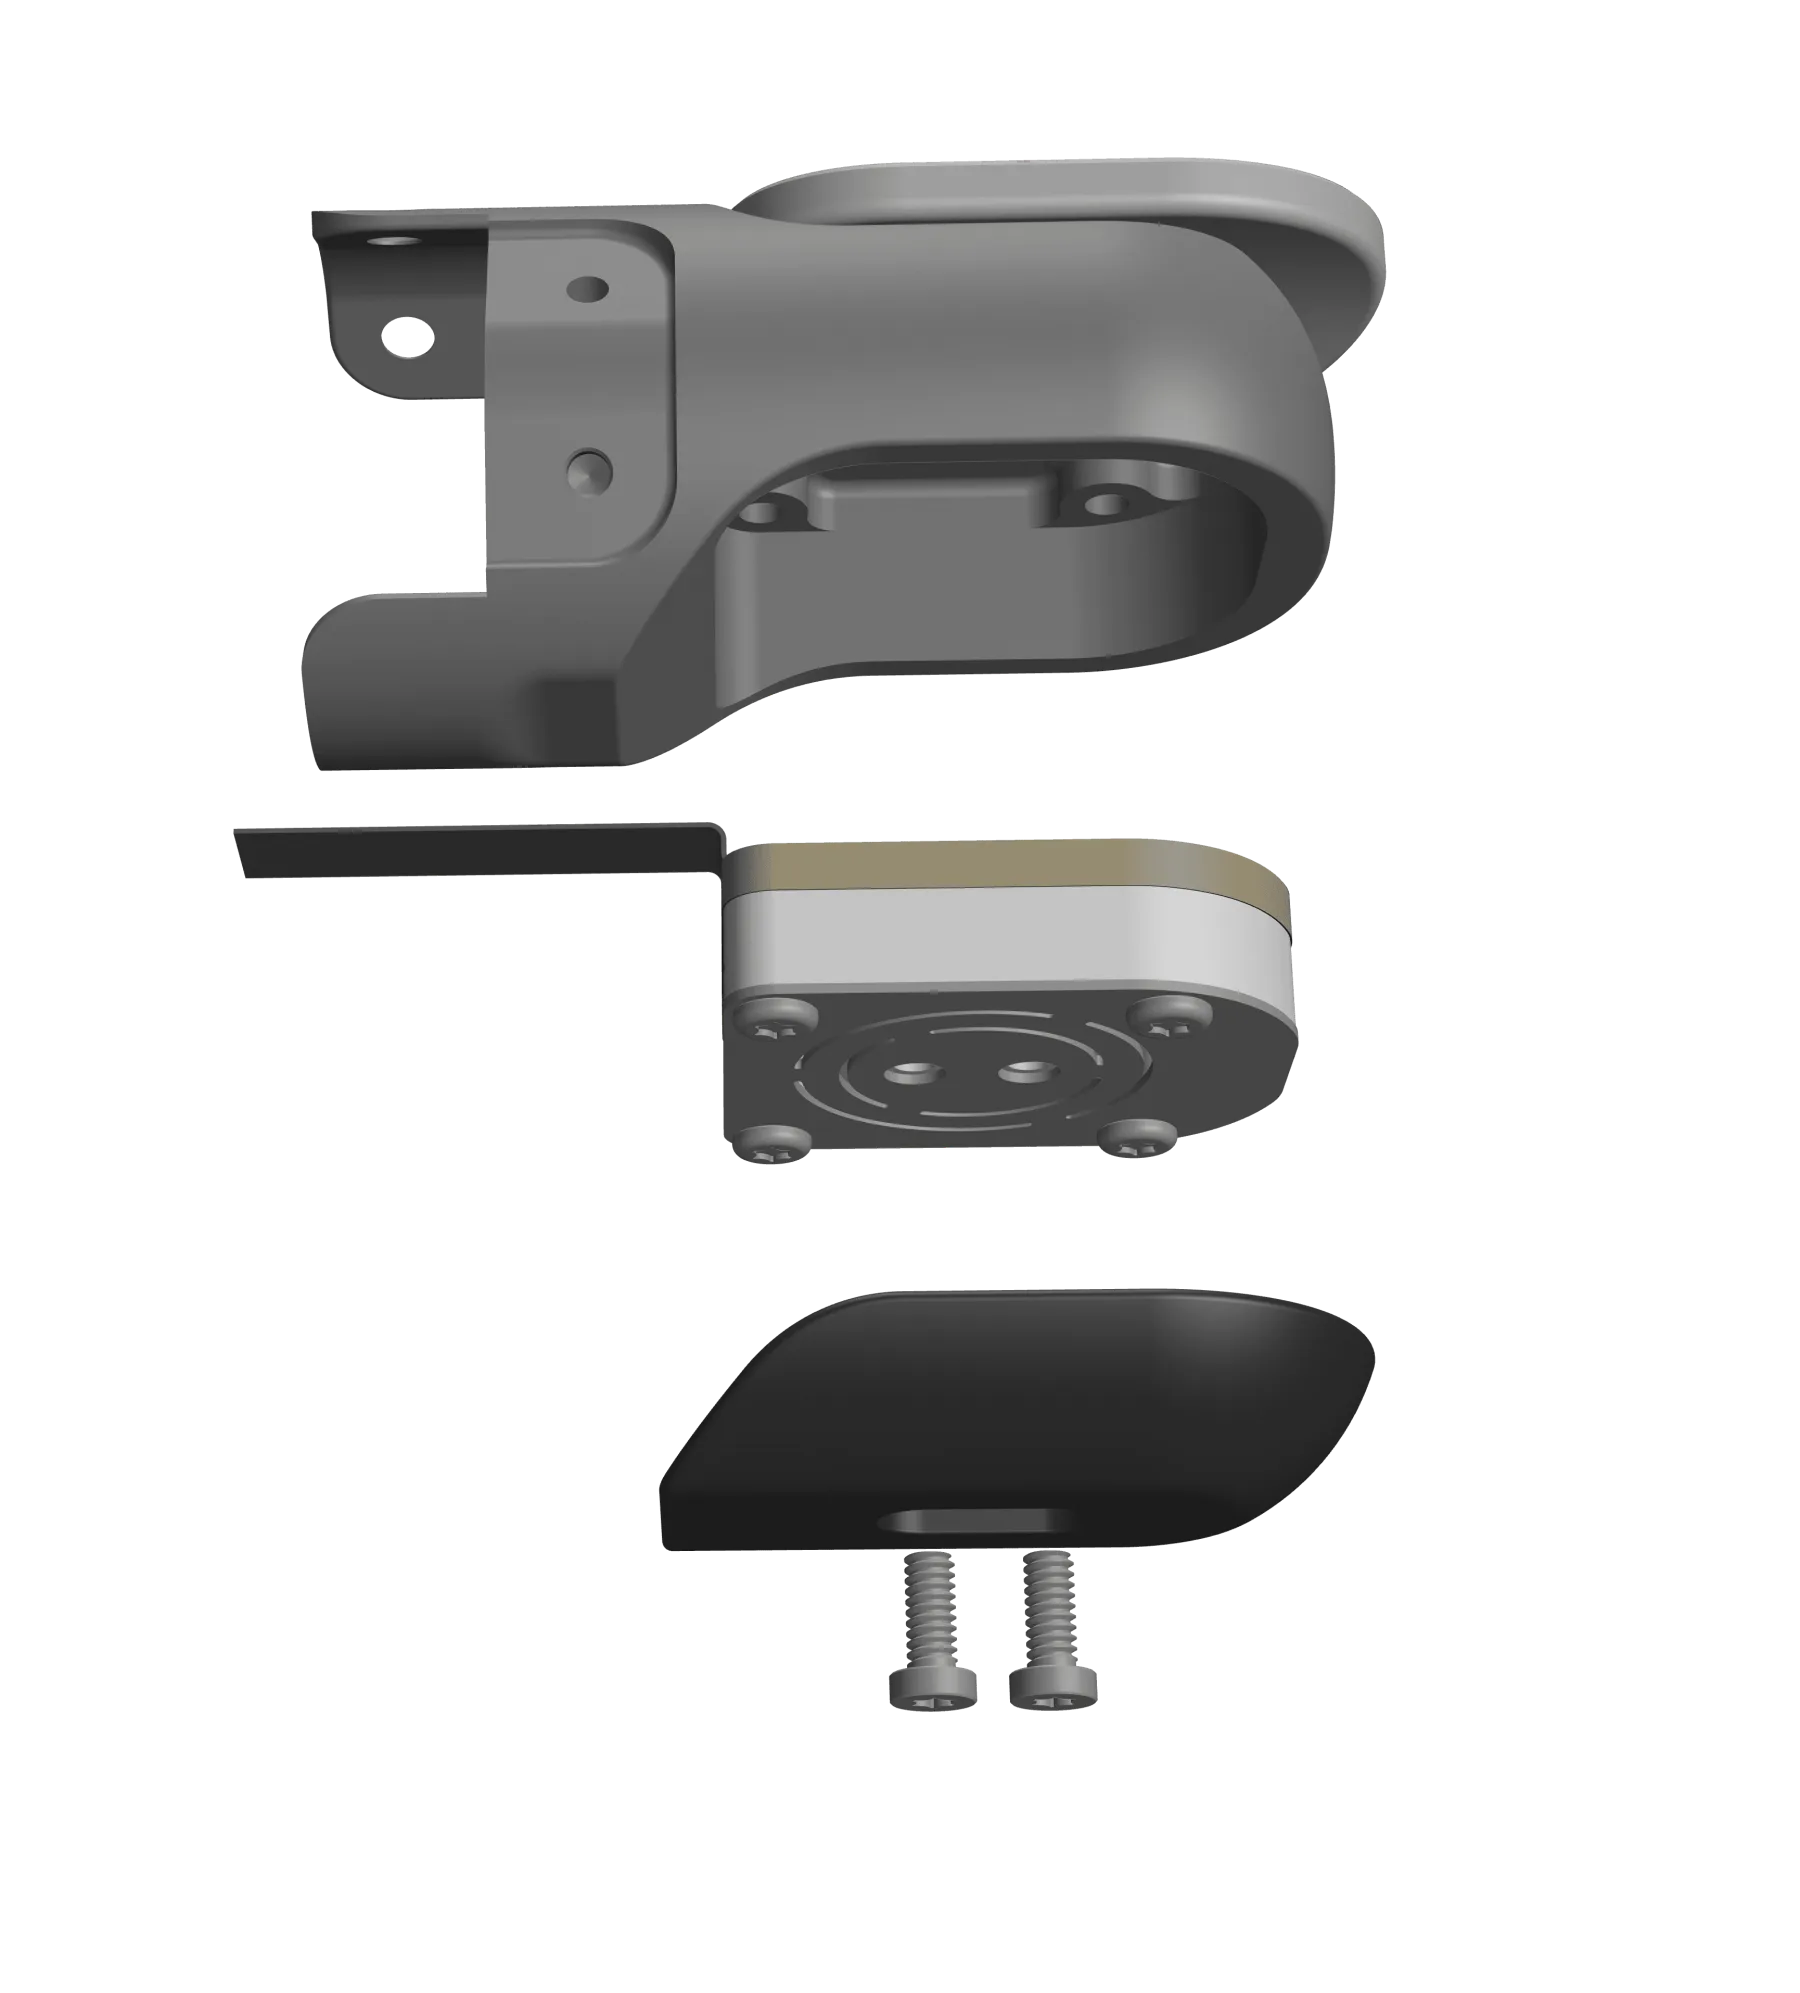
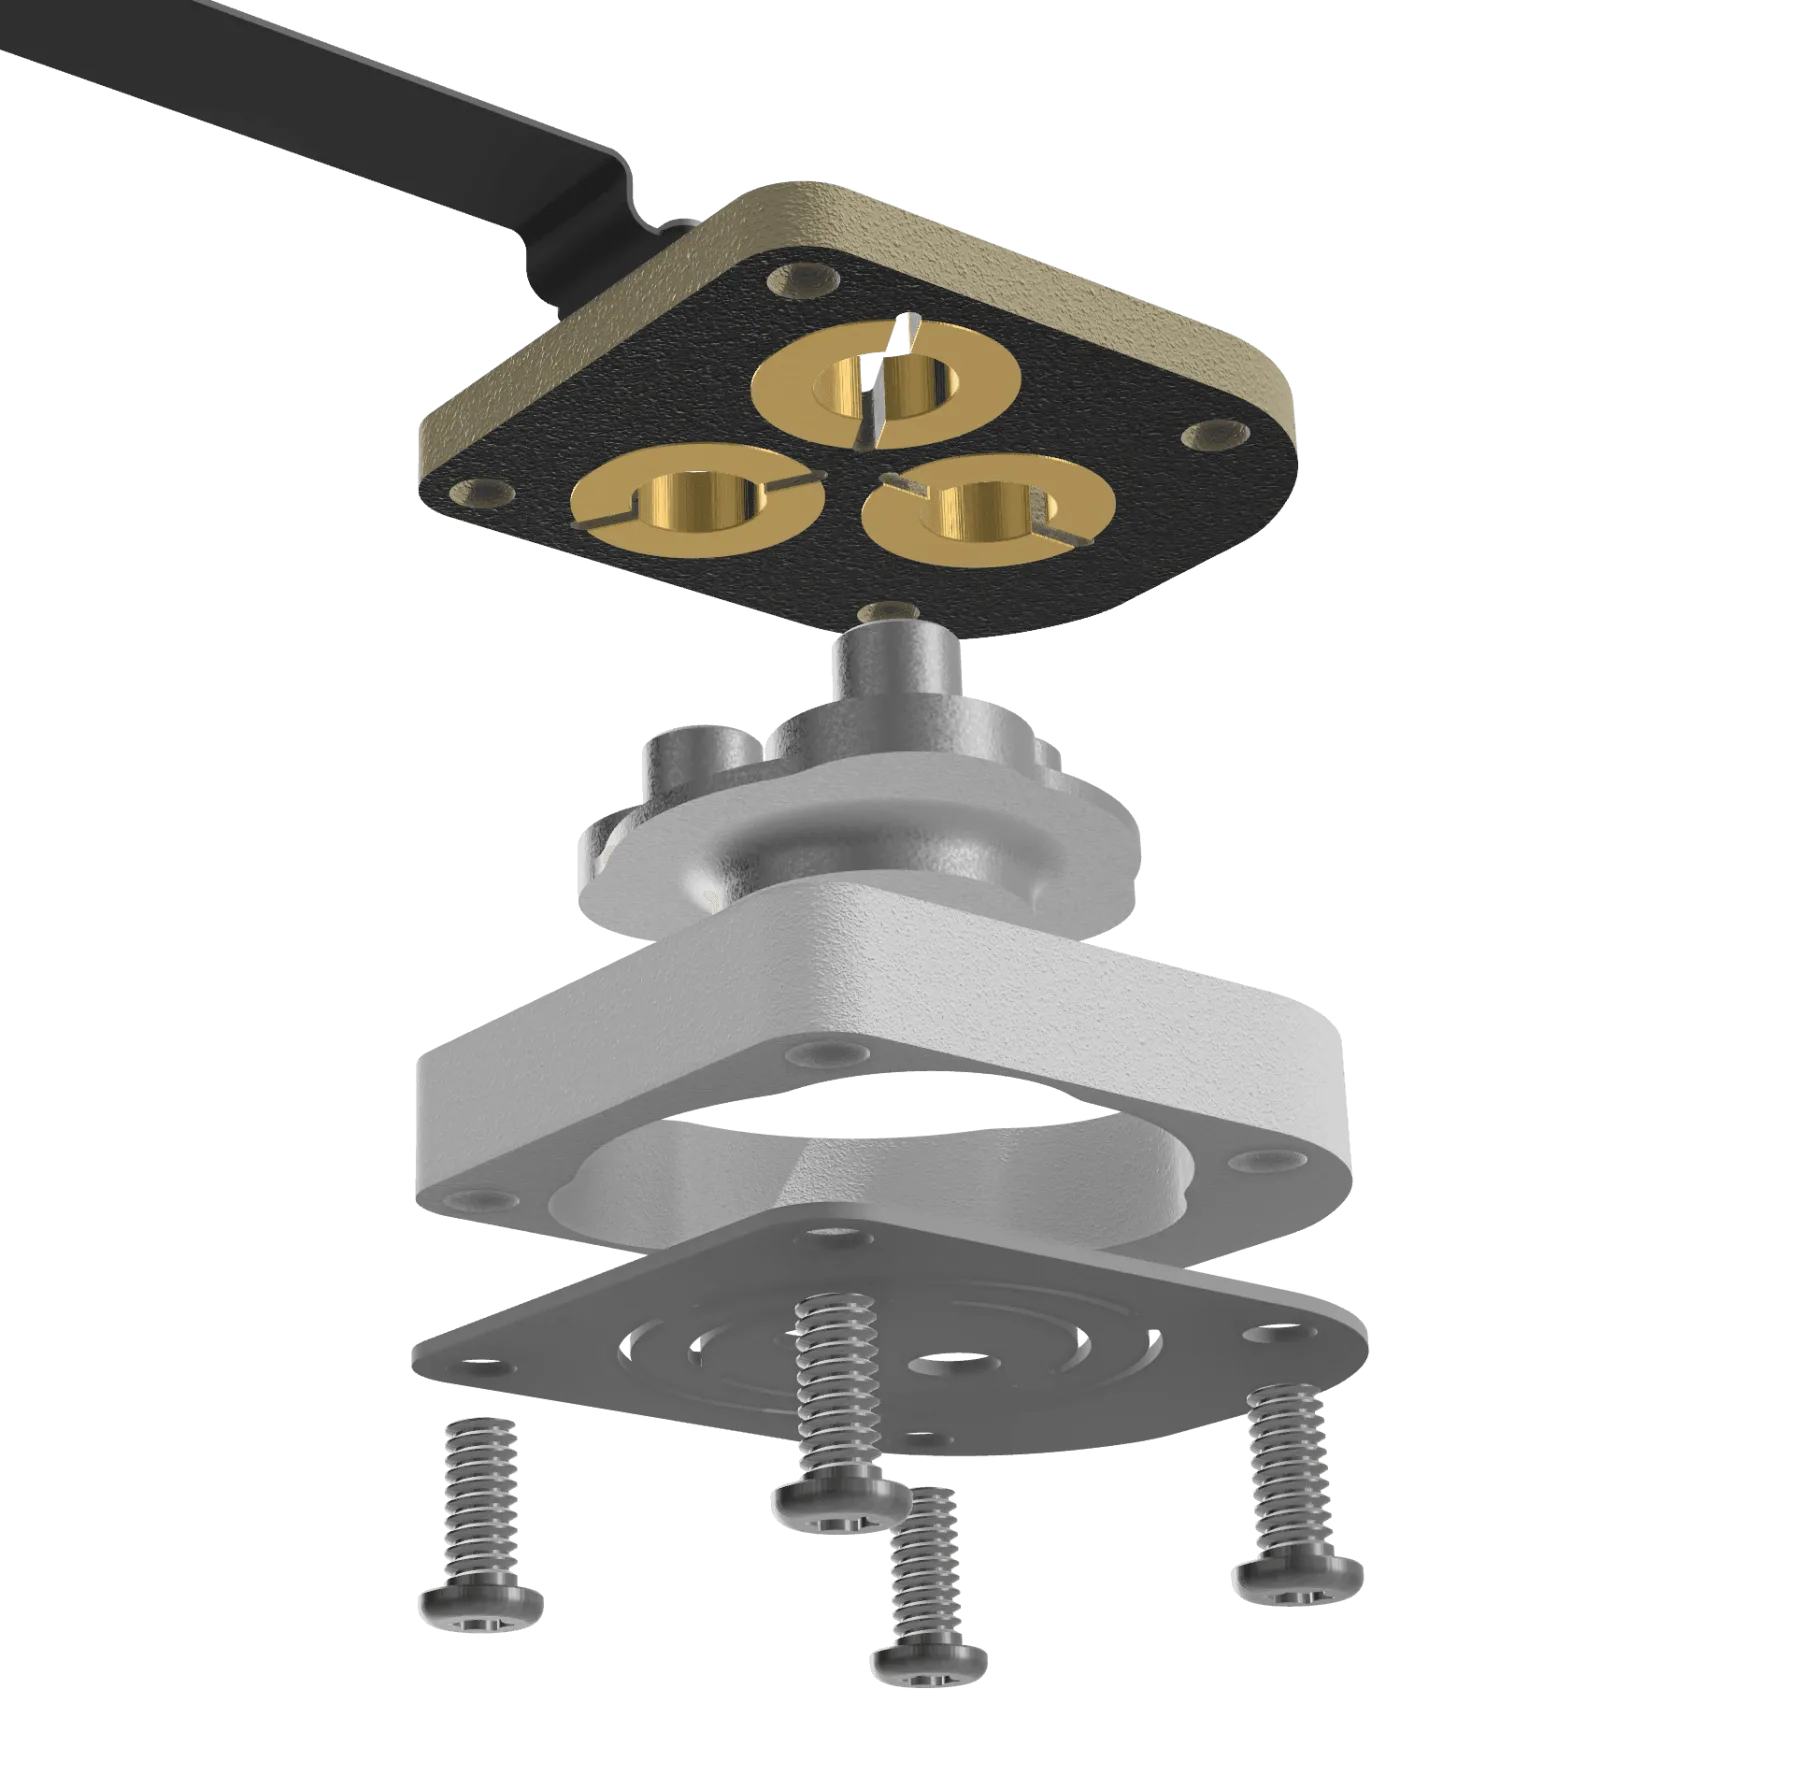
Custom Force & Torque Finger Tip Sensor
Each fingertip is instrumented with a custom capacitive sensor that resolves all six components of contact load: Forces (Fx, Fy, Fz) and Torques (Tx, Ty, Tz) on all axes. It mounts directly to the modular actuator module, giving every finger full contact feedback with no external sensing.