Engineering
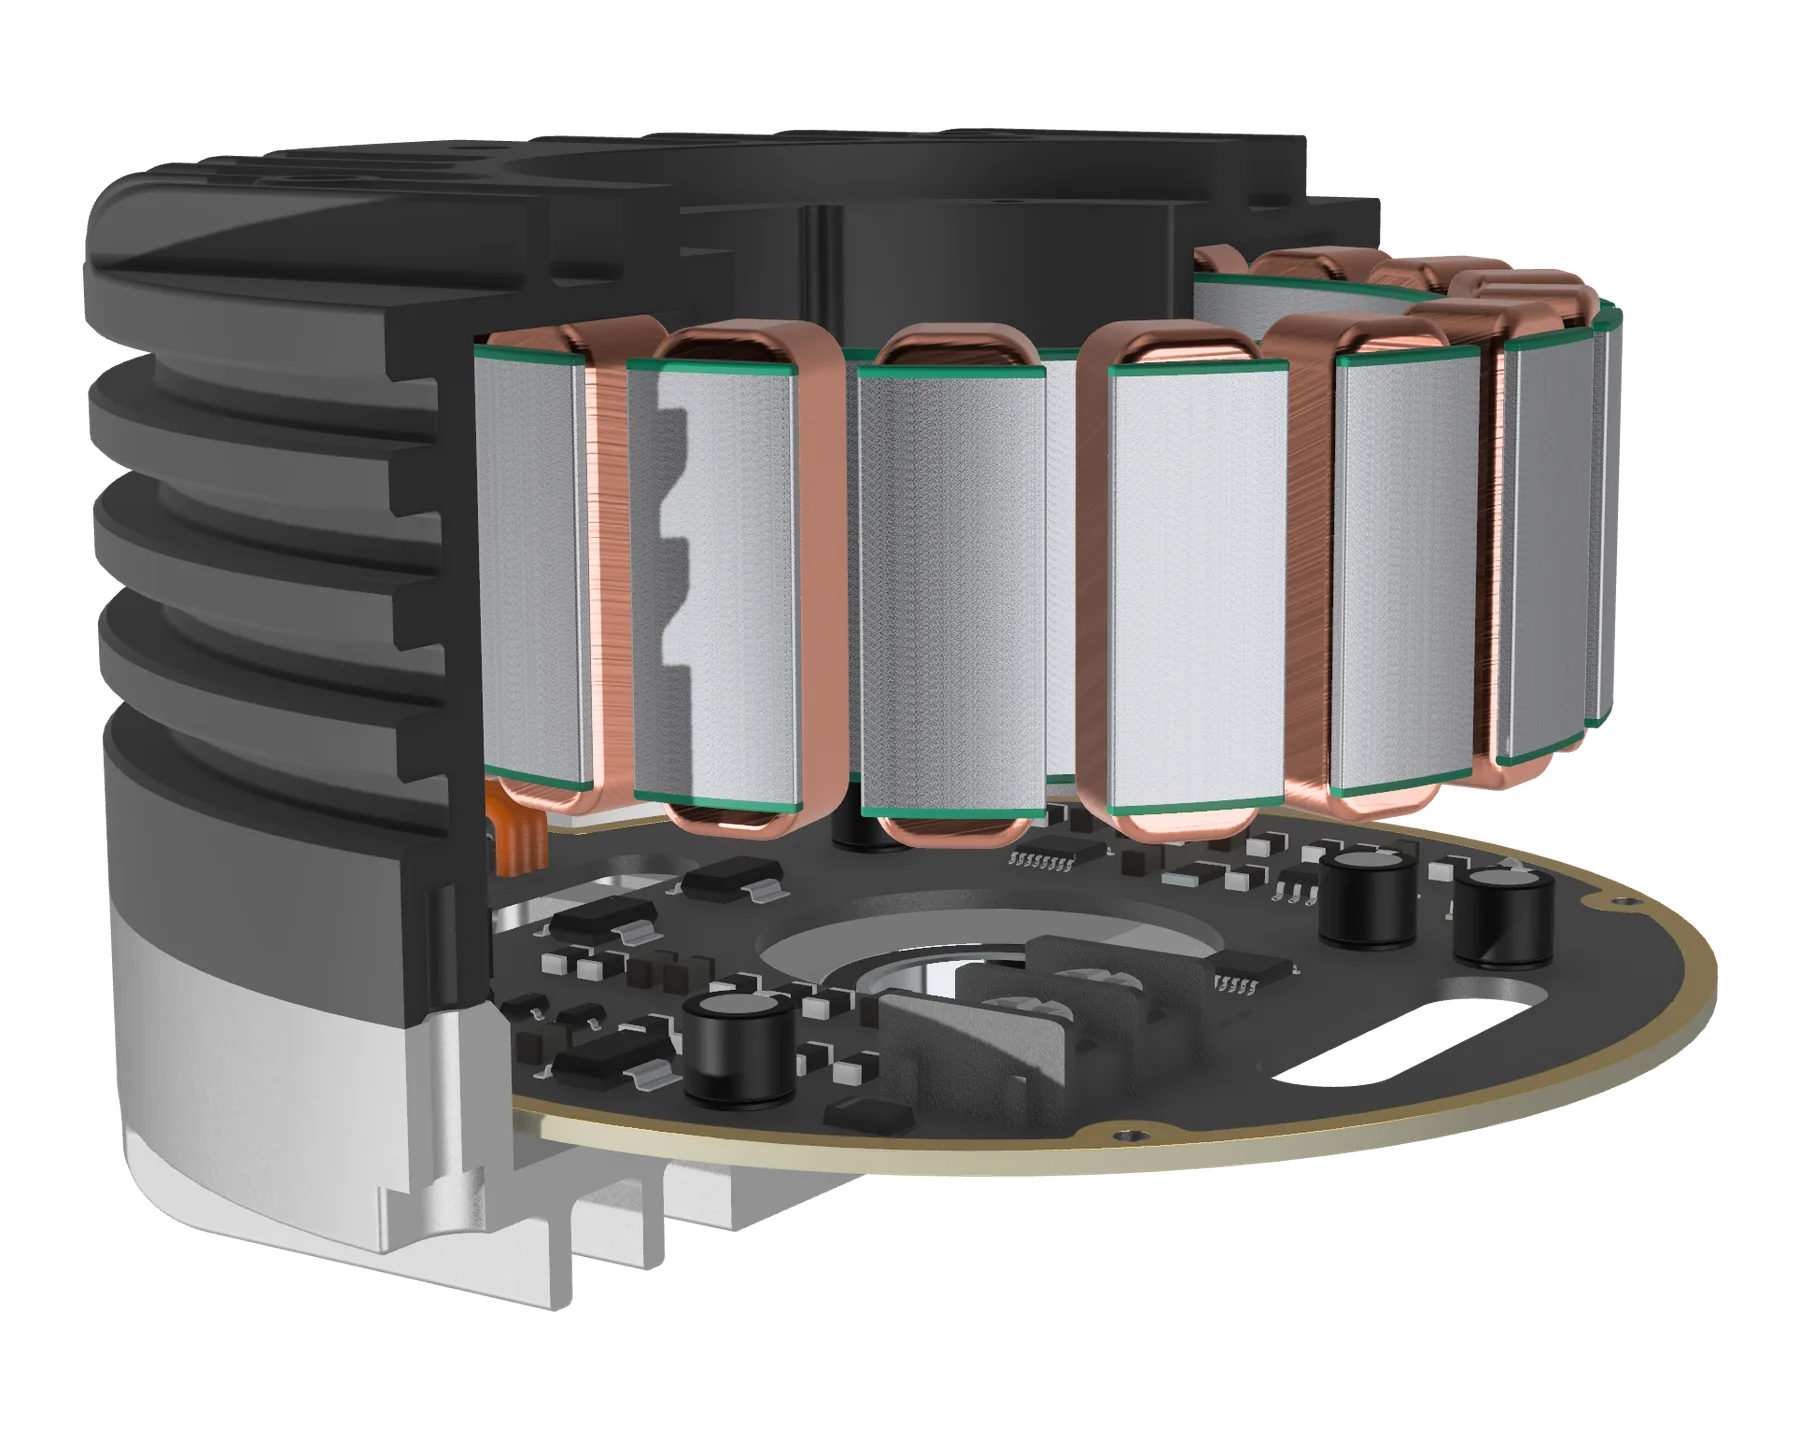
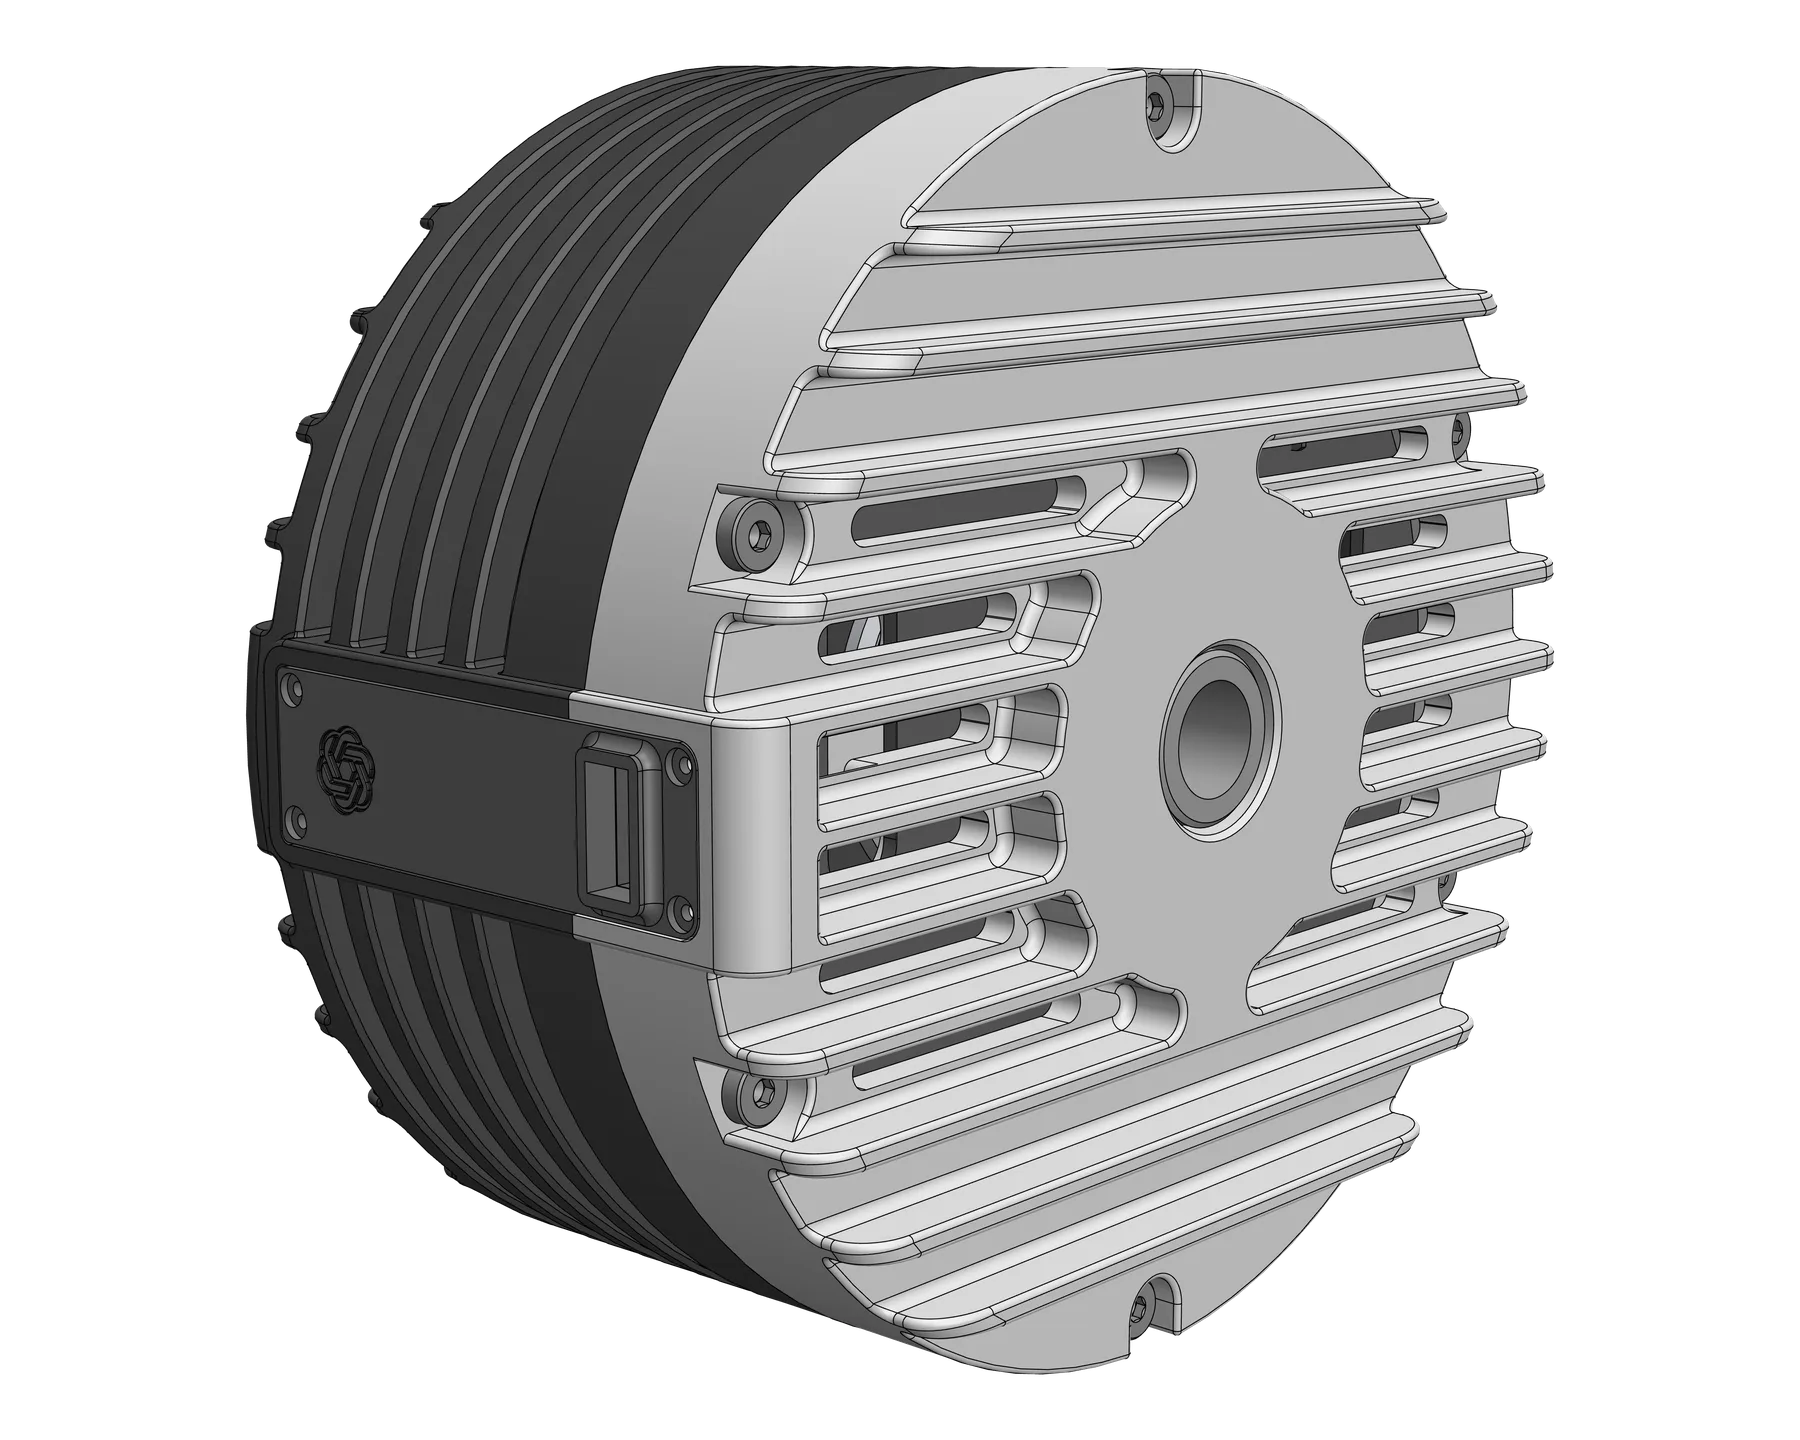
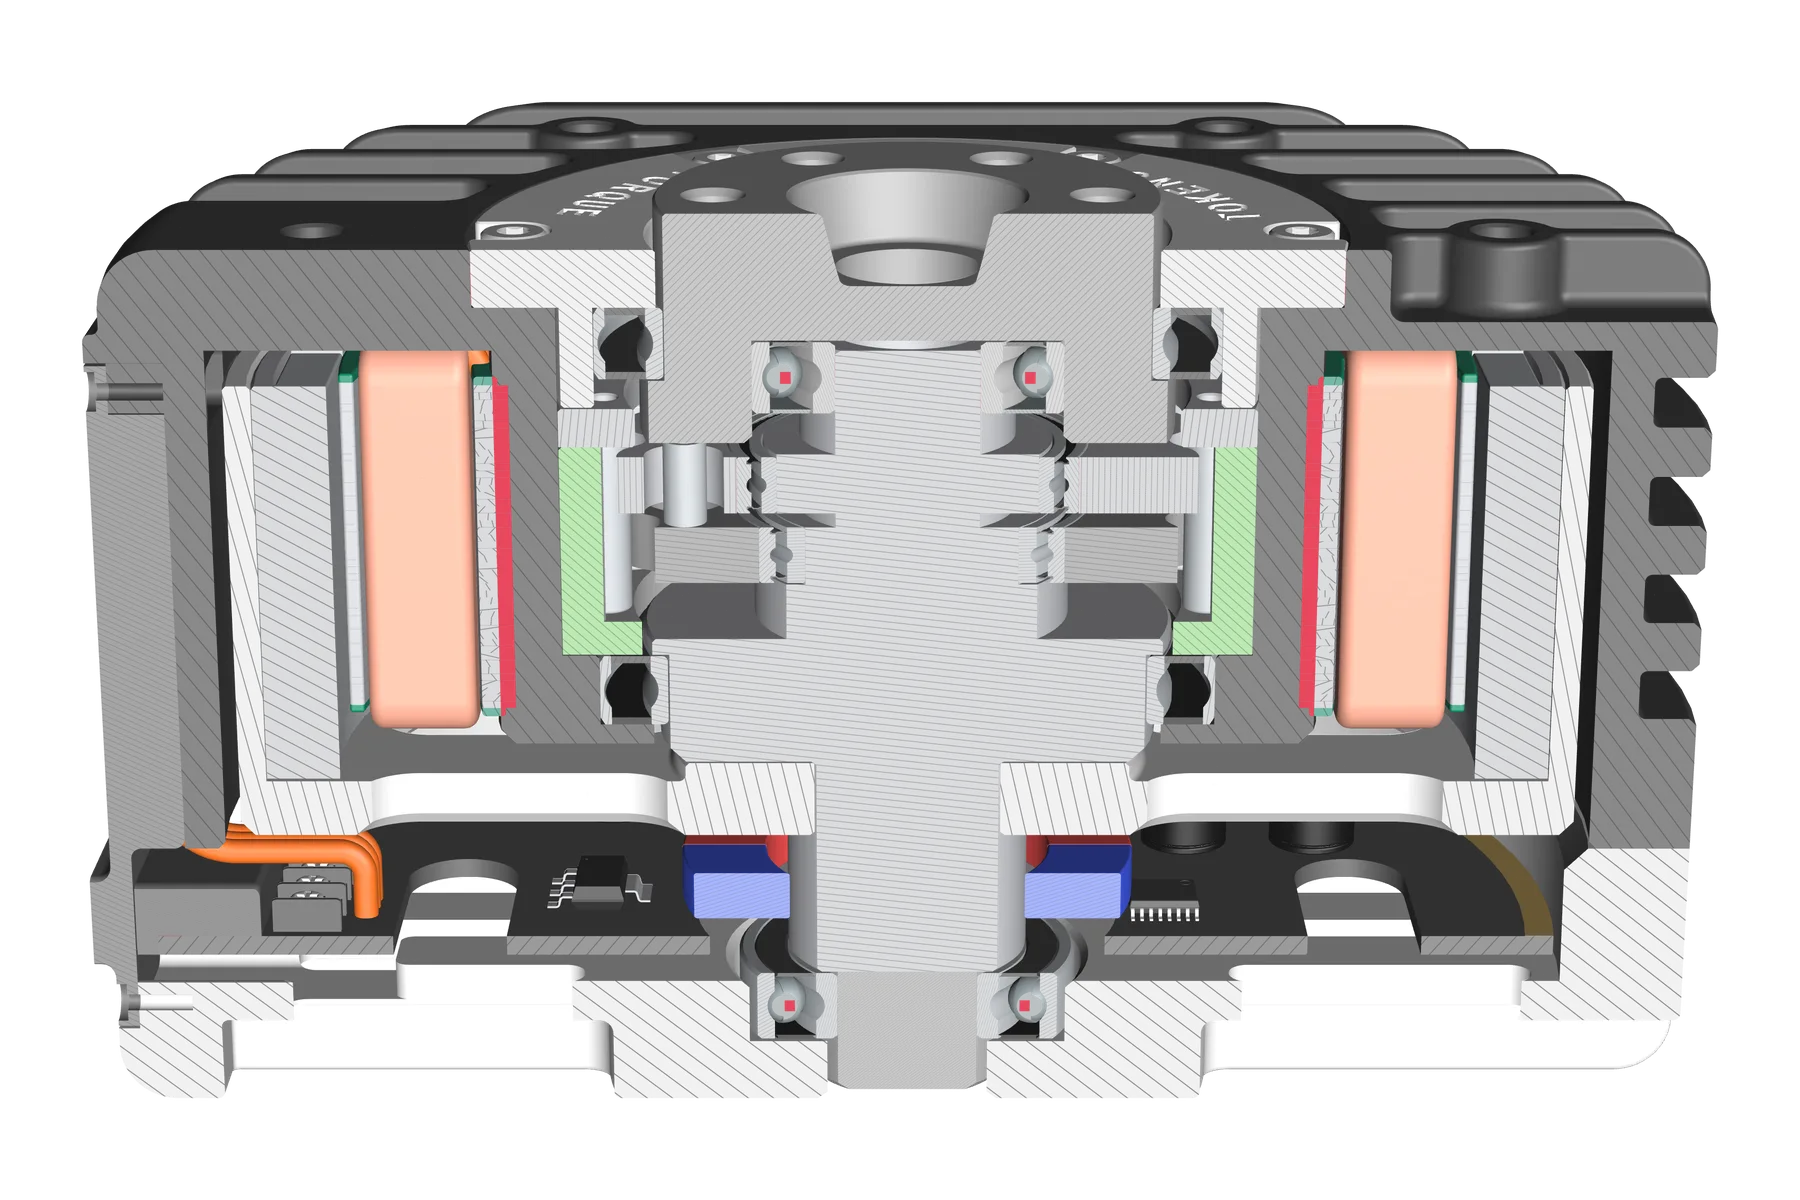
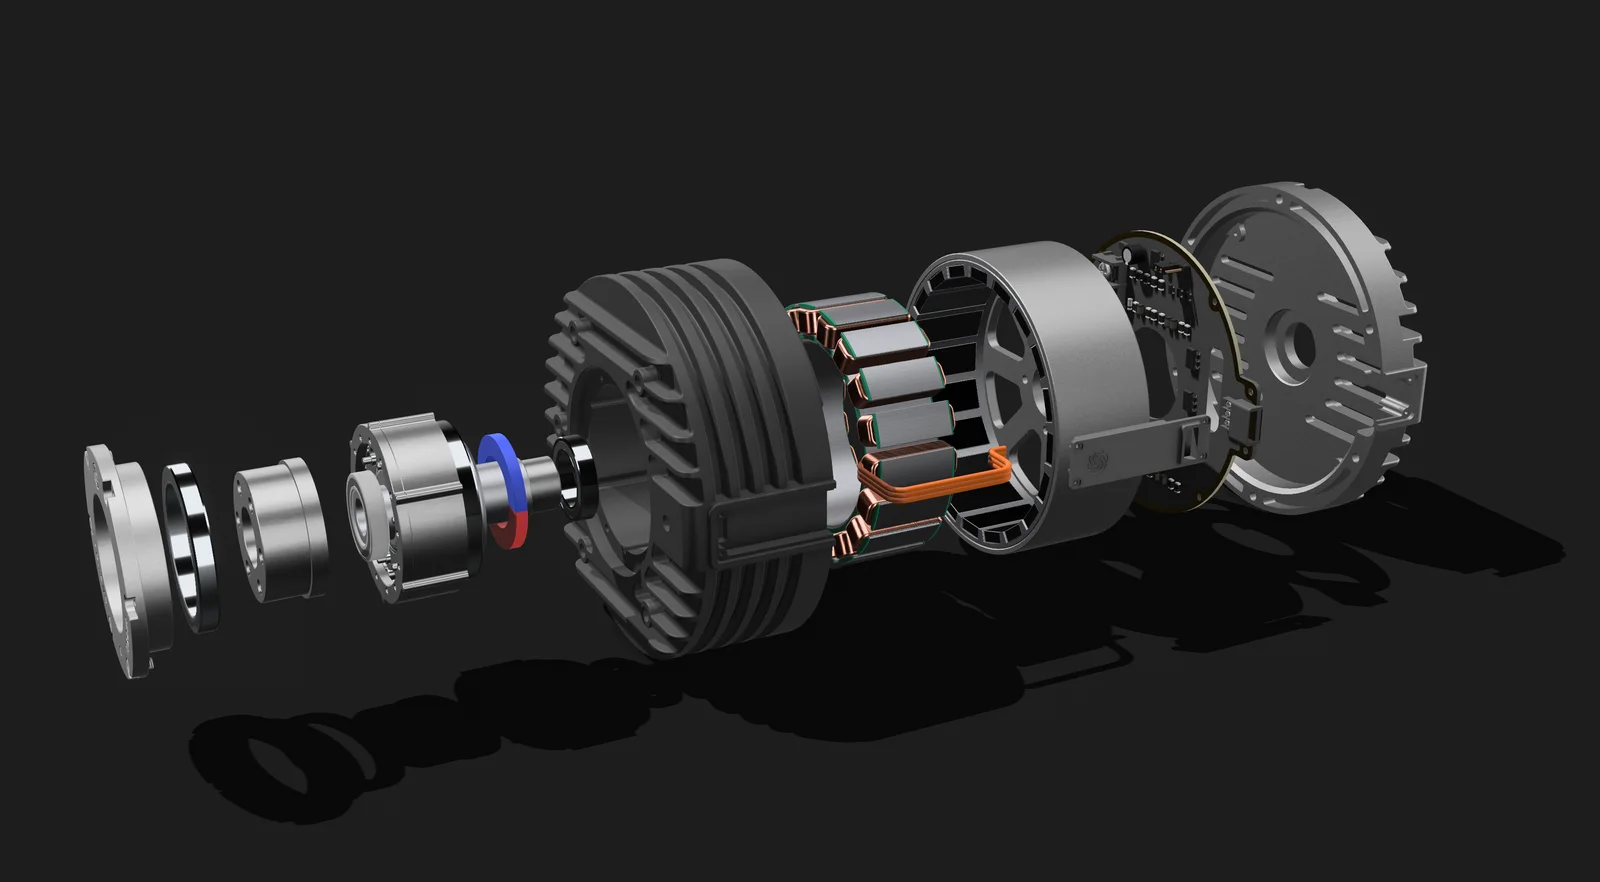
Below is a brief overview of the design and engineering of the QDD actuator, a quasi-direct-drive joint for robots. It covers the motor architecture, the 12 : 1 cycloidal reducer, and the integration of the driver, encoder and bearings into one compact module.
Dual radiator thermal layout
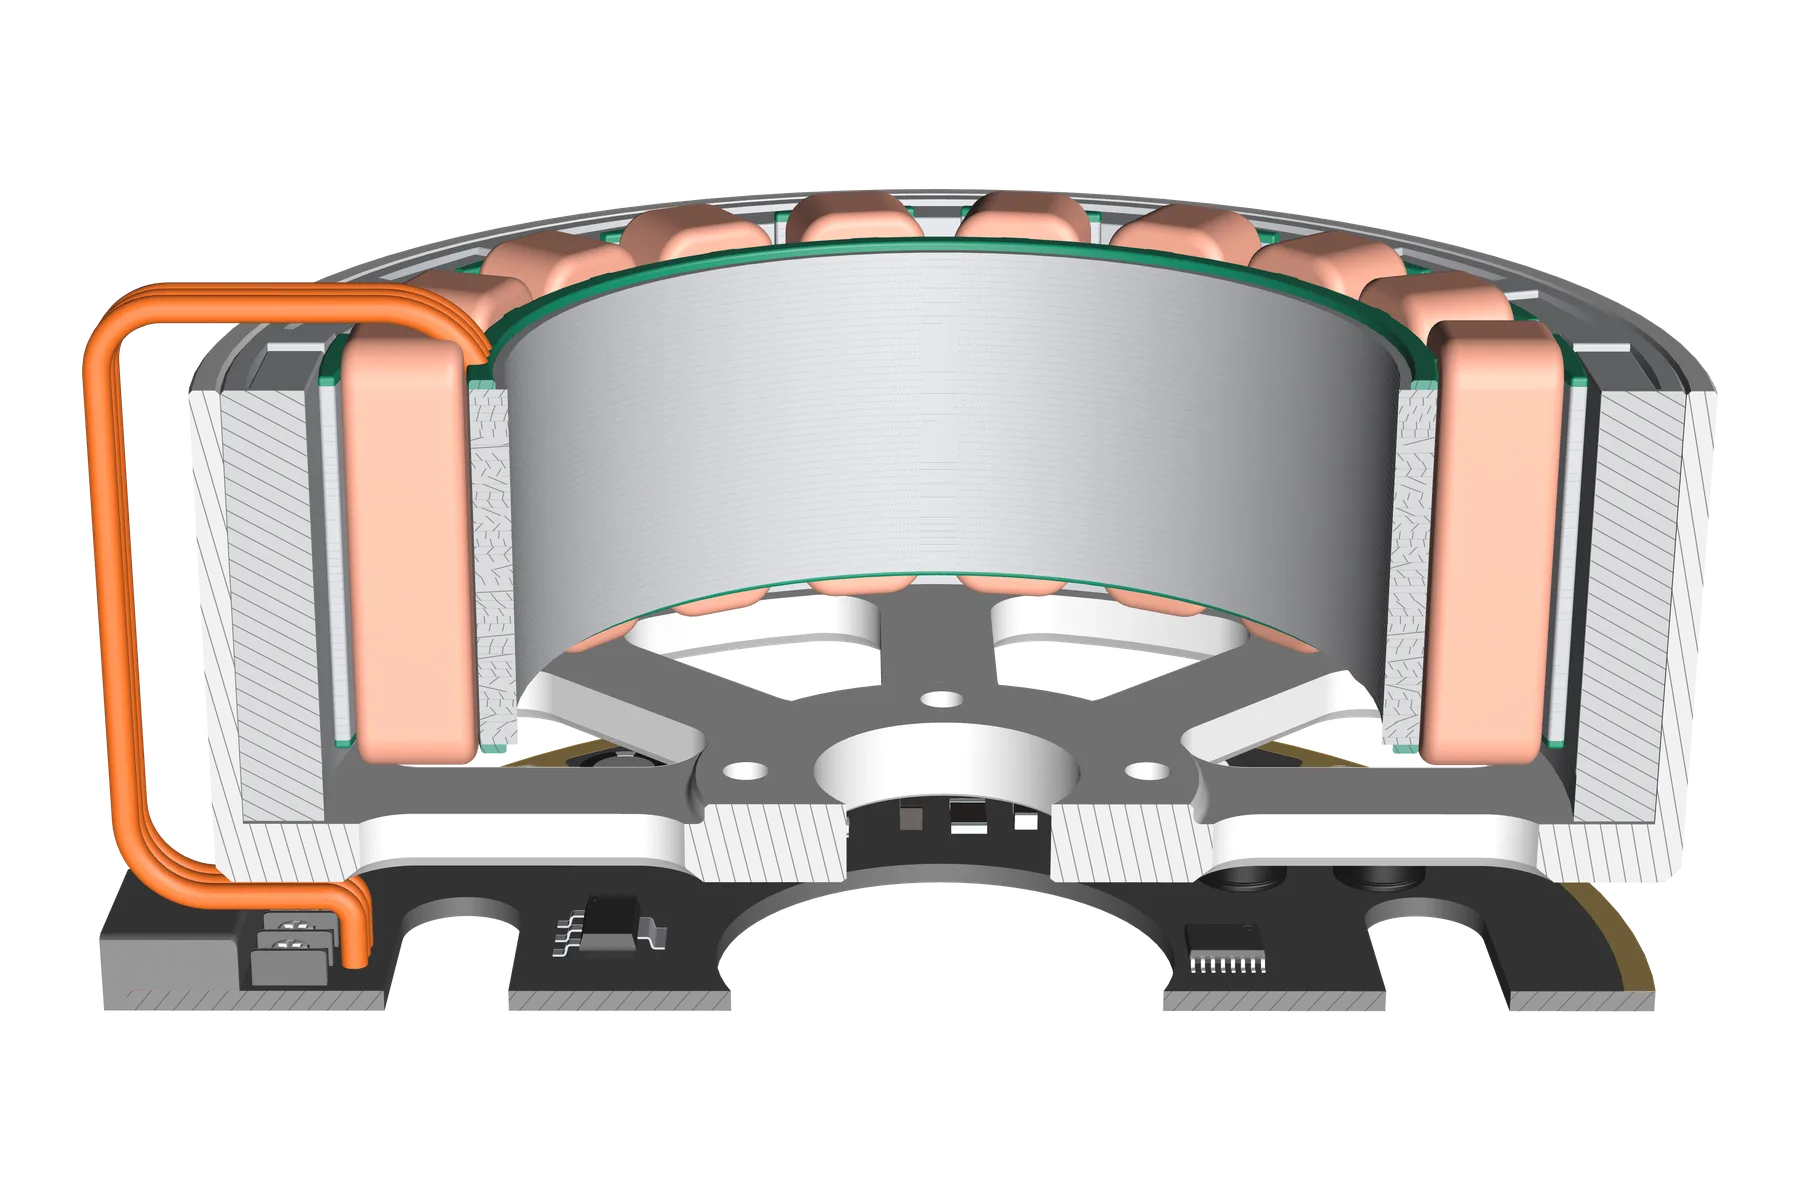
The stator is mounted directly to the finned housing, and similarly the control electronics mounts to a finned rear cover on the opposite face of the enclosure. Each heat source (stator and electronics) gets its own radiator instead of sharing one buried plate, which improved thermal performance of the actuator compared to conventional layouts where the electronics is mounted behind the stator which limits the effective surface area of heat exchange.
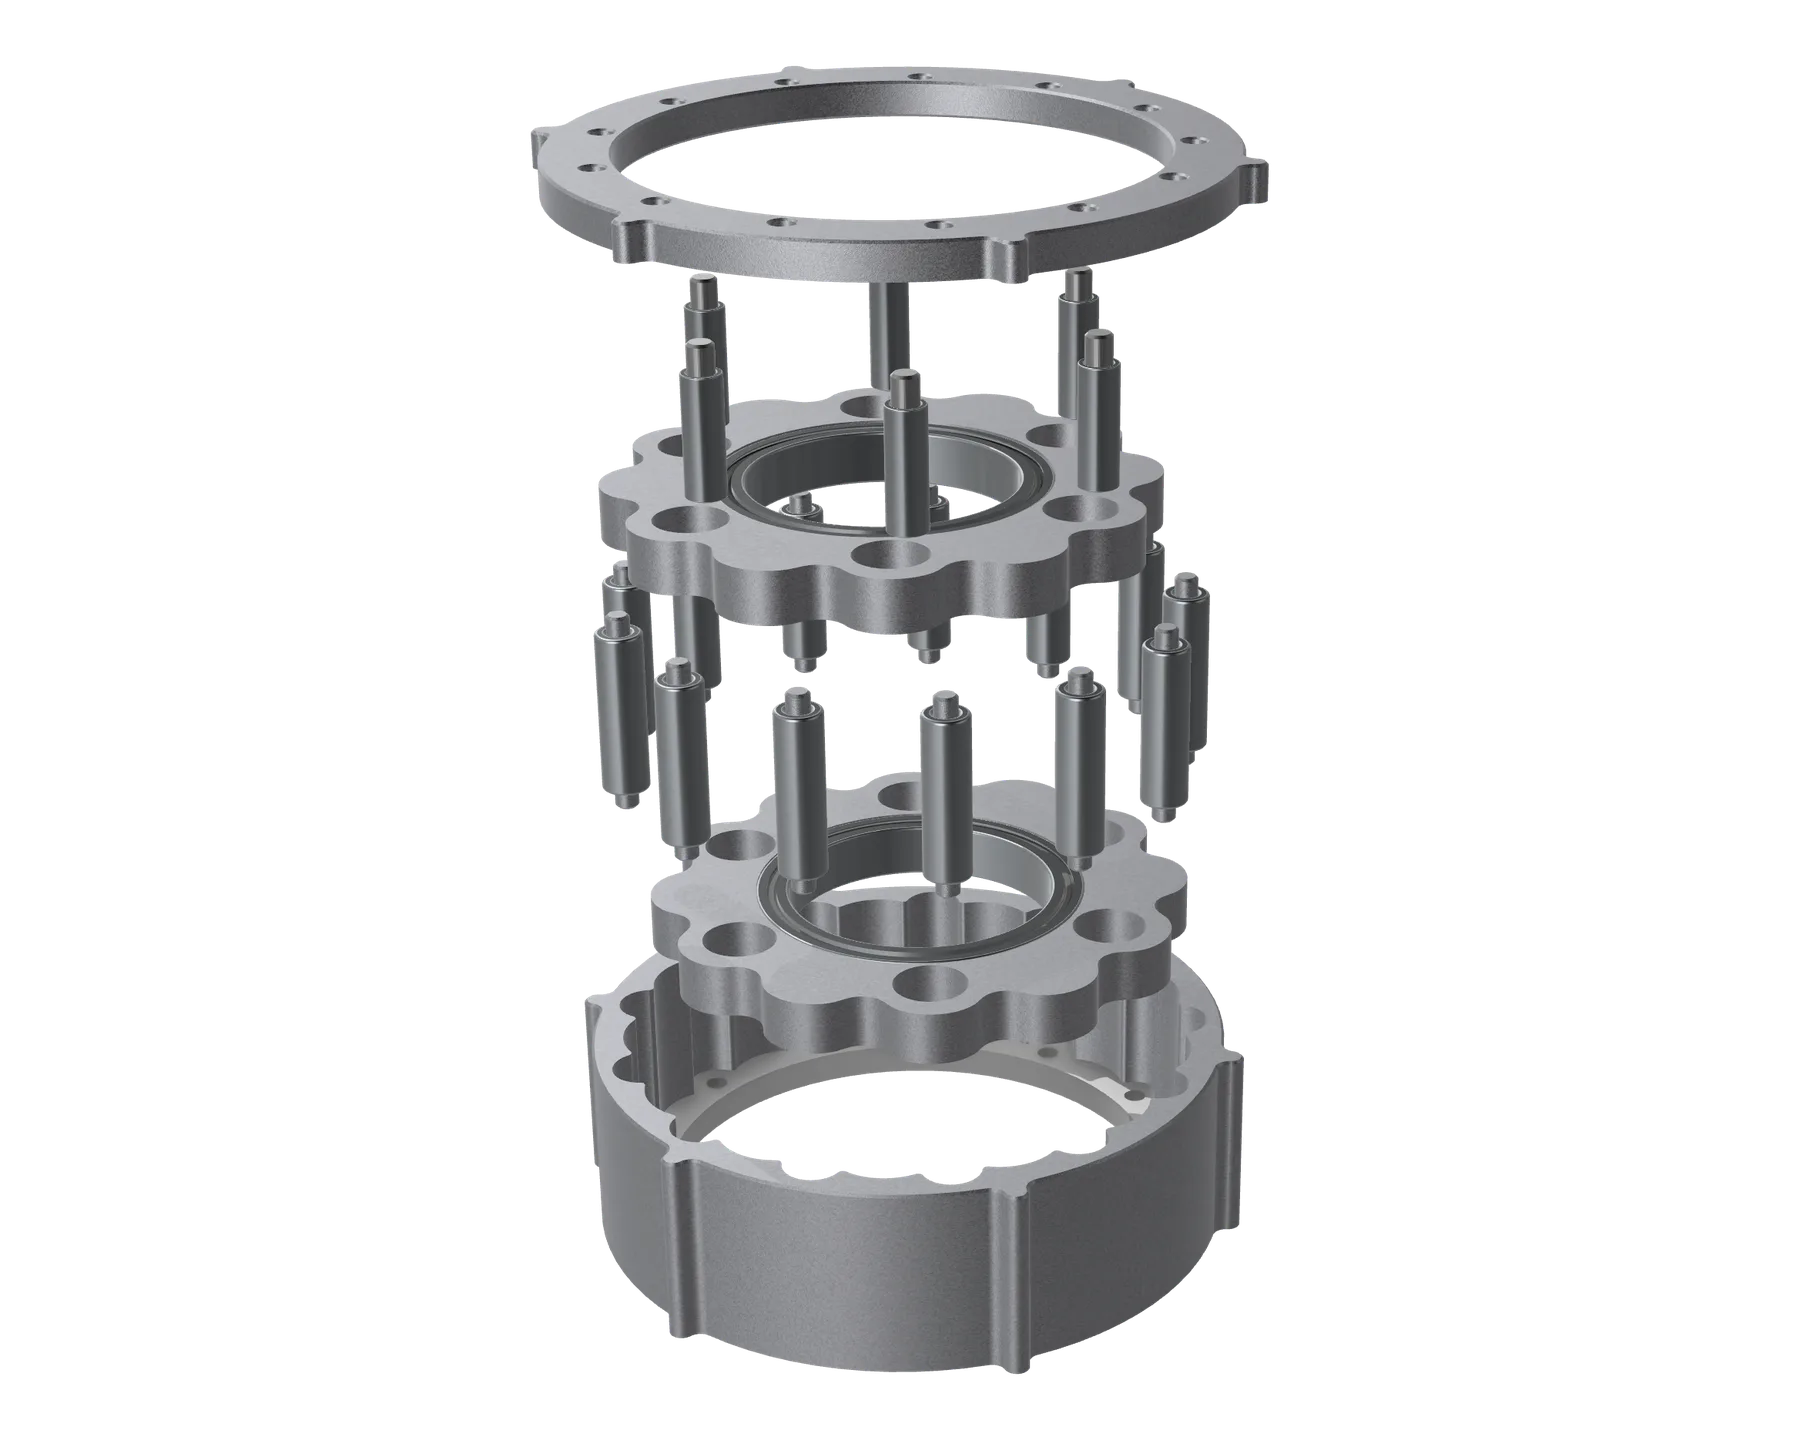
Discs, pins and rollers
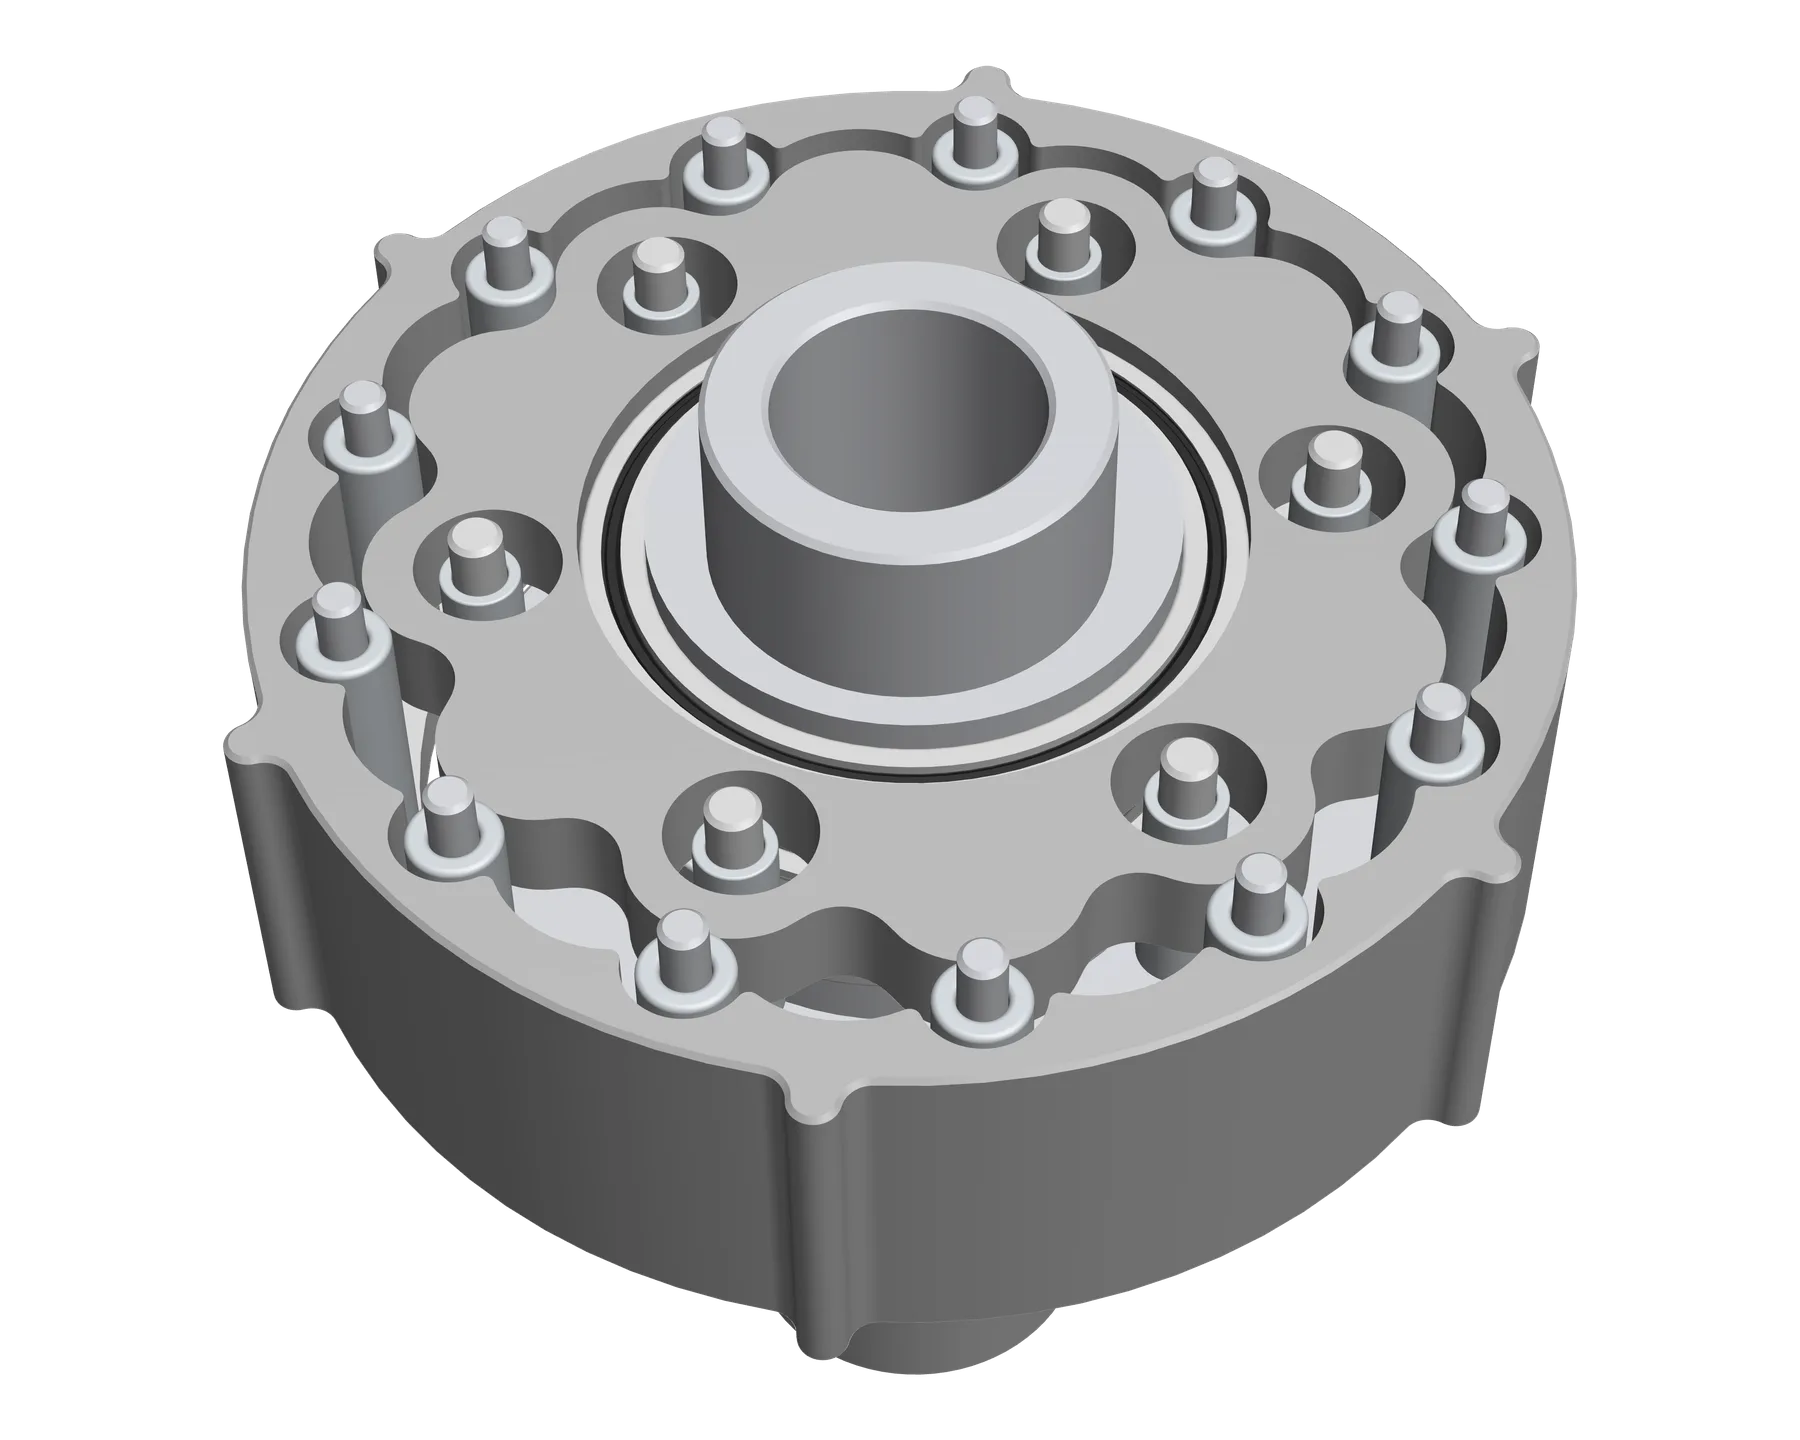
Cycloidal module